A new force/torque sensor that goes beyond six-axis force measurement
What is N-GFS (Numerous-Gauge Force Sensor)?
NISSHA’s proprietary force/torque sensor incorporates a larger number of strain gauges than conventional designs, enabling the integration of functionalities beyond six-axis force measurement.
In addition to conventional six-axis force/torque measurement—including forces along the X, Y, and Z axes and moments about the Mx, My, and Mz axes—N-GFS can incorporate advanced capabilities not available in conventional force/torque sensors.
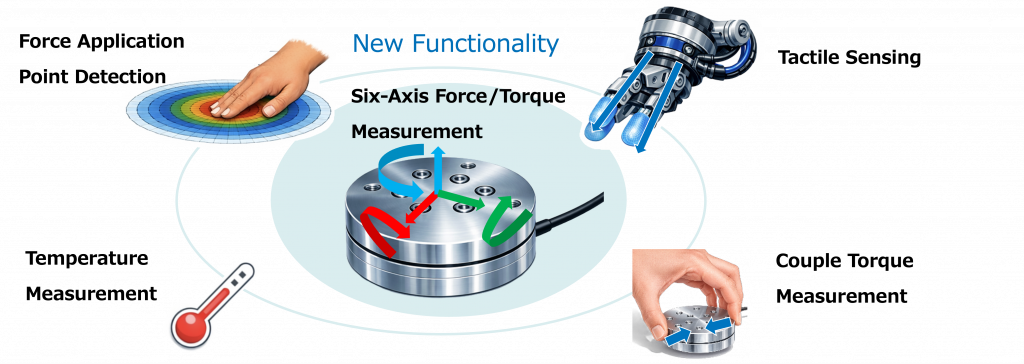
These technologies may enable data that previously required multiple types of sensors to be acquired using only our N-GFS multi-modal tactile sensor. Furthermore, by leveraging this data for Physical AI training, N-GFS has the potential to contribute to more advanced and precise robot control.
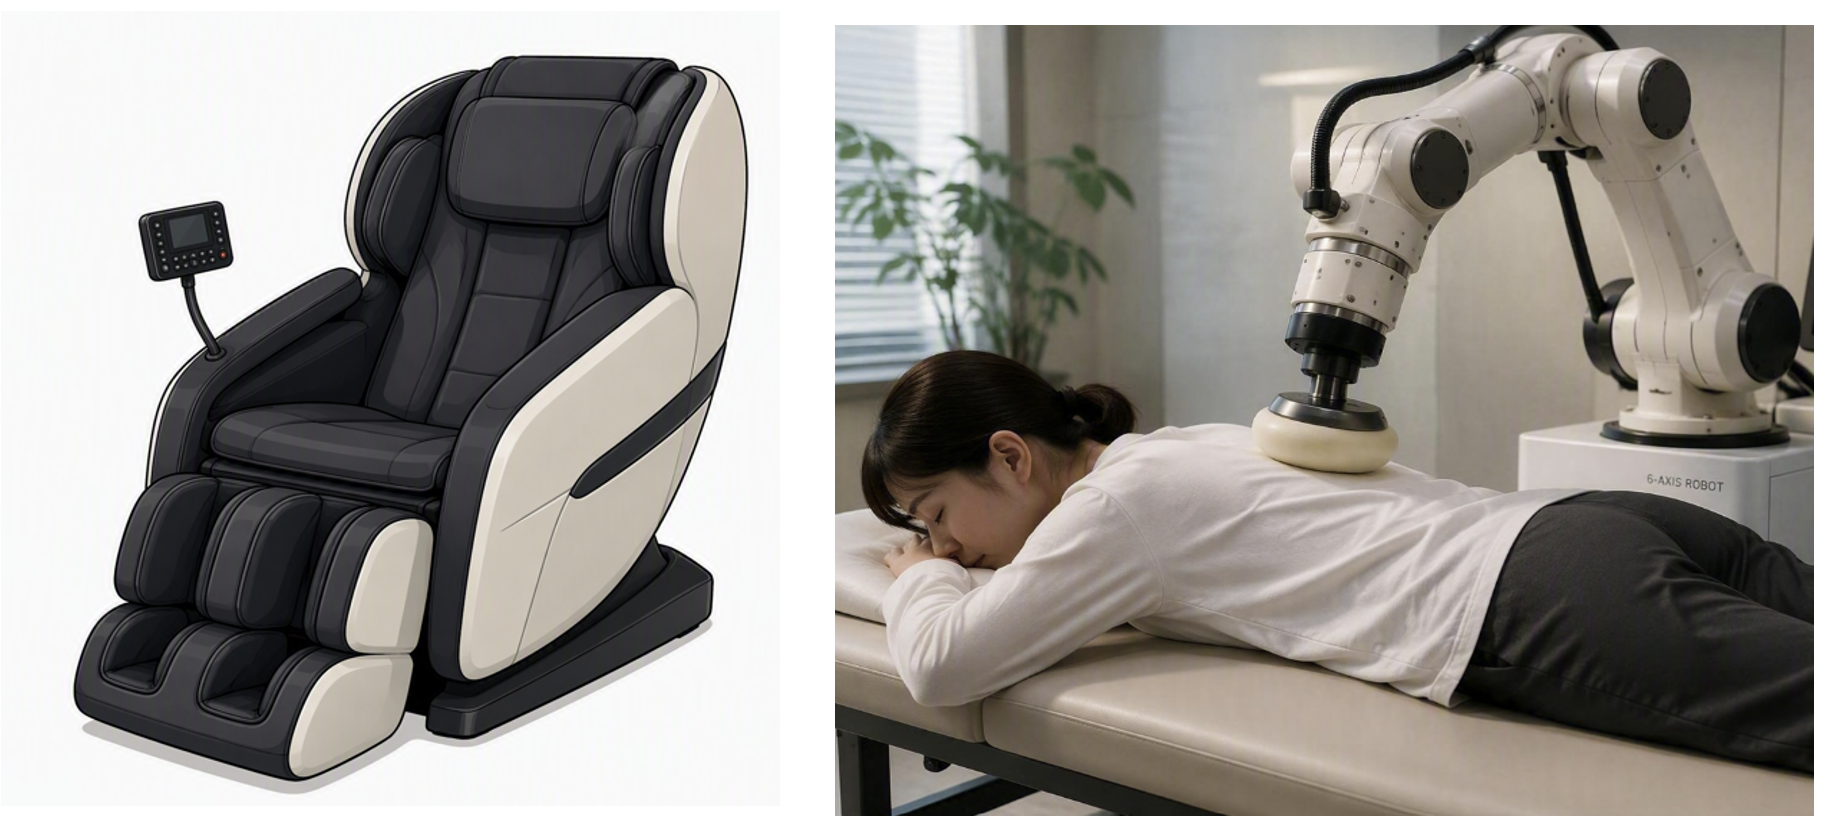
Potential to support adaptive control by identifying skeletal structure and muscle characteristics for each body type.
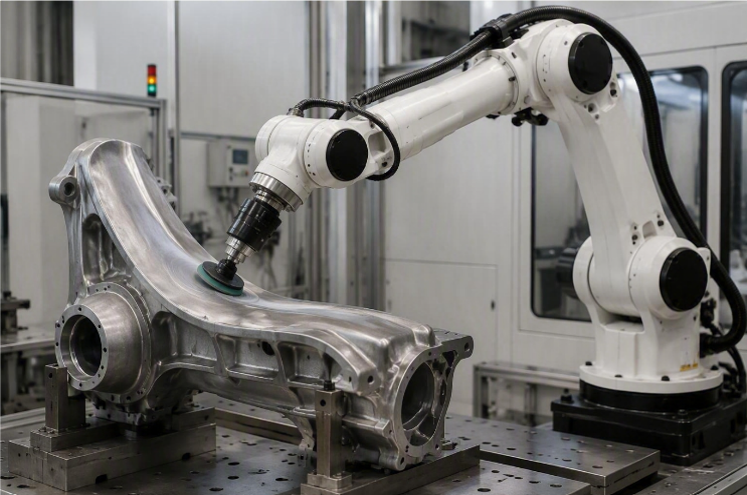
Potential to enable high-precision robotic polishing by monitoring contact conditions between the polishing tool and the workpiece, as well as the amount of material removed.
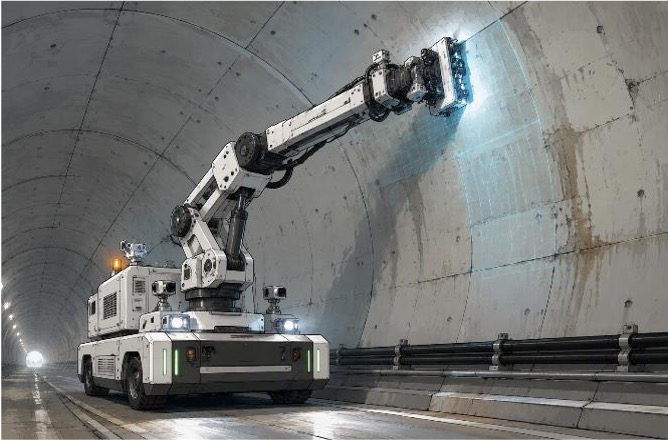
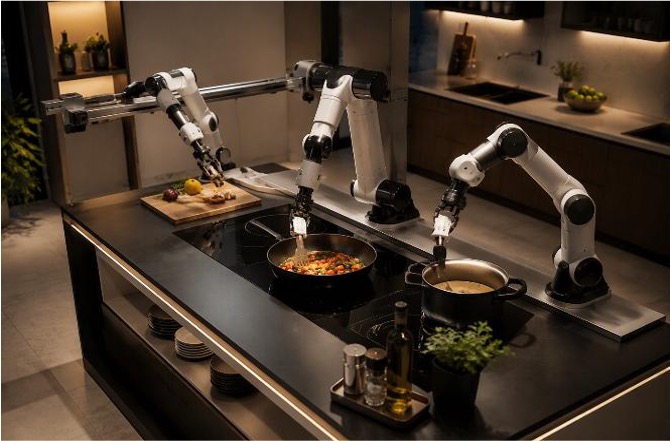
Suitable for environments with significant temperature fluctuations and for long-duration operations requiring temperature-drift compensation.
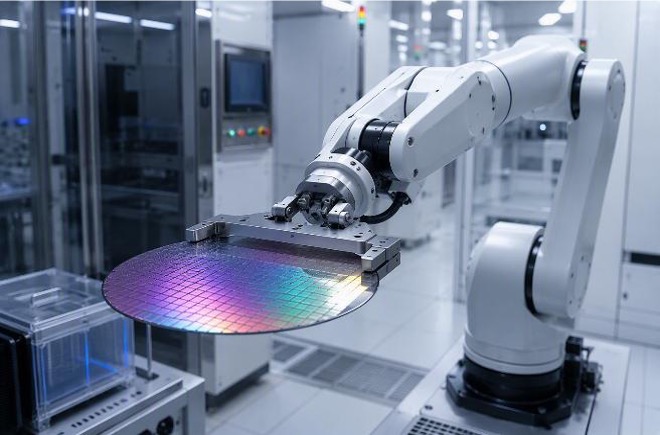
Potential to enable the safe handling and gripping of delicate objects through highly accurate force measurement.
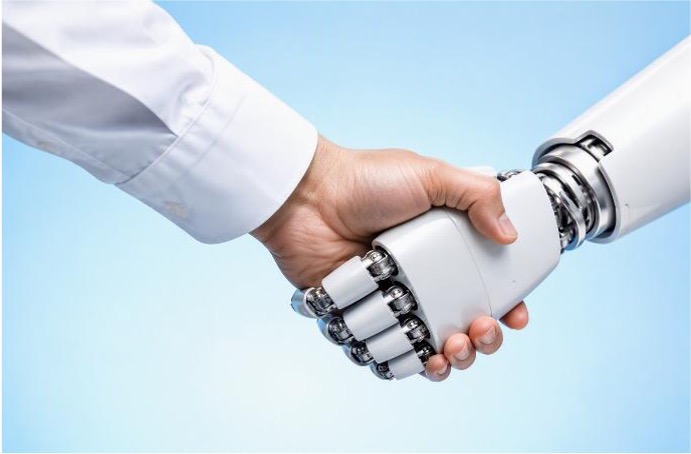
Potential to enable precise control of humanoid robot hands through advanced force-sensing capabilities.
* Some images on this page were generated using AI for illustrative purposes.
Please feel free to contact us for any questions or concerns.
CLICK